

Product Description
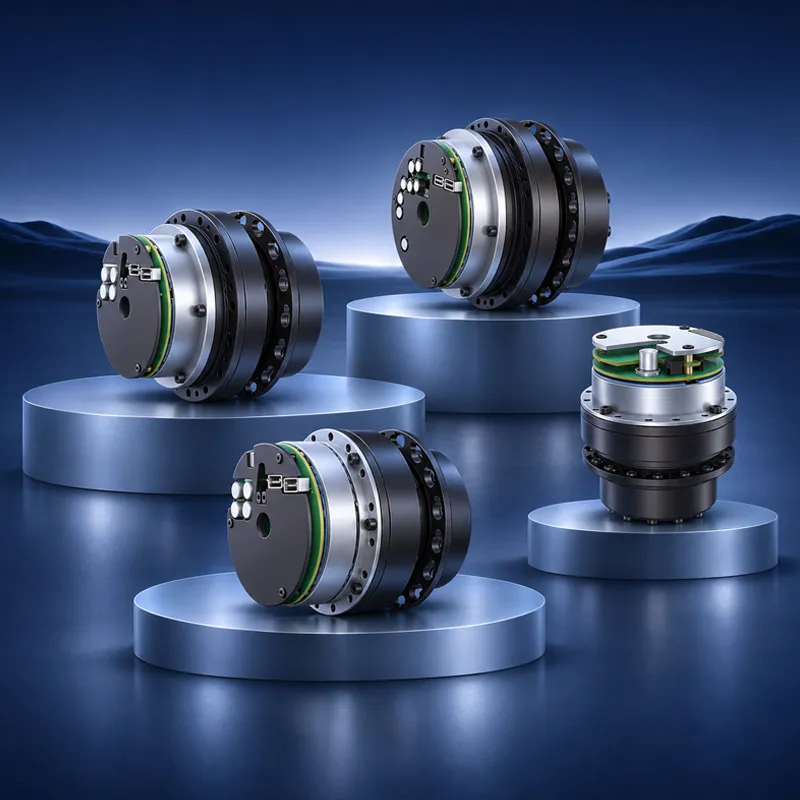
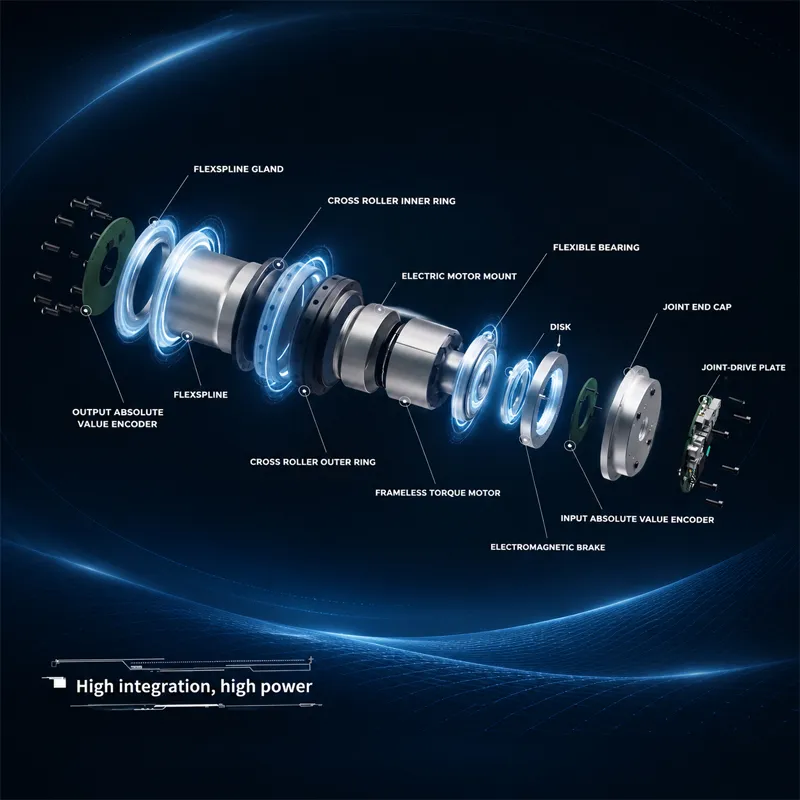
The TSJA Series Ultra-Lightweight Integrated Harmonic Joint Actuator combines a servo motor and a specially designed harmonic reducer in a compact unit. It integrates dual absolute encoders, an electromagnetic brake, and a joint drive unit, delivering high torque density and a highly integrated design for robotic applications.
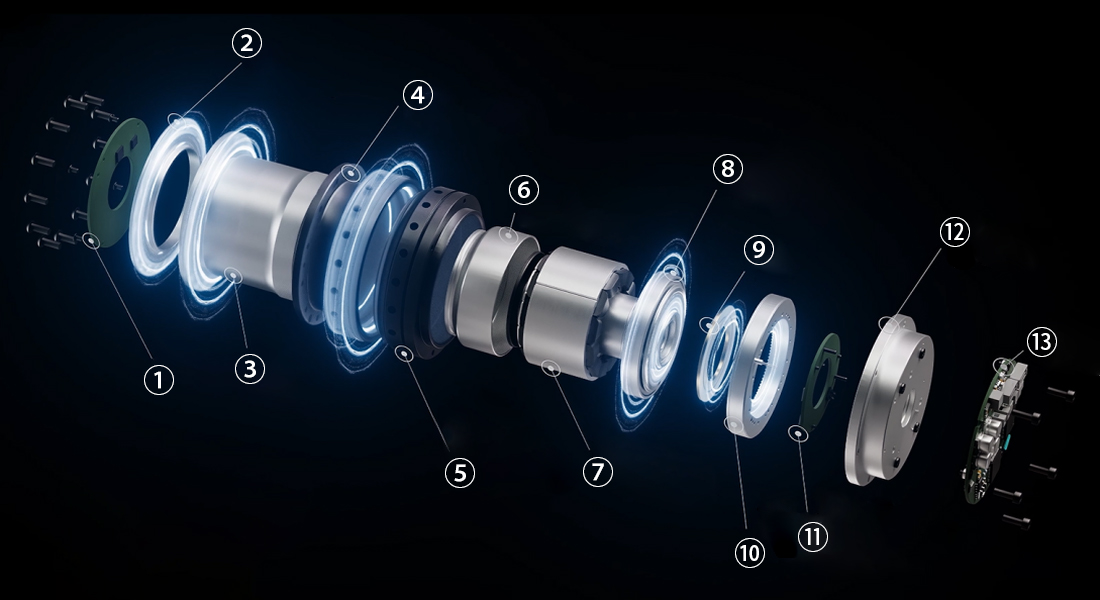
①Output Absolute Value Encoder ②Flexspline Gland ③Flexspline ④Cross Roller Inner Ring ⑤Cross Roller Outer Ring ⑥Electric Motor Mount ⑦Frameless Torque Motor ⑧Flexible Bearing ⑨Disk ⑩Electromagnetic Brake ⑪Input Absolute Value Encoder ⑫Joint End Cap ⑬Joint Drive Plate
Product parameters
Item | TSJA25-XXBTEF/TSJA25-XXBTES | TSJA20-XXBTEF/TSJA20 -XXBTES | TSJA17-XXBTEF/TSJA17-XXBTES | TSJA14-XXBTEF/TSJA14 -XXBTES | ||||||||||||
Gear Ratio | 50 | 80 | 100 | 120 | 160 | 50 | 80 | 100 | 120 | 50 | 80 | 100 | 120 | 50 | 80 | 100 |
Rated Torque (Nm) | 51 | 82 | 86 | 86 | 86 | 33 | 43 | 52 | 52 | 20 | 28 | 31 | 31 | 6.8 | 9.8 | 9.8 |
Start/Stop Peak Torque (Nm) | 127 | 178 | 204 | 217 | 229 | 73 | 96 | 107 | 113 | 44 | 56 | 70 | 70 | 24 | 30 | 35 |
Maximum Permissible Average Load Torque (Nm) | 72 | 113 | 137 | 137 | 137 | 44 | 61 | 63 | 63 | 34 | 35 | 51 | 51 | 9 | 14 | 14 |
Maximum Permissible Instantaneous Torque (Nm) | 242 | 232 | 369 | 395 | 408 | 127 | 165 | 189 | 189 | 91 | 113 | 143 | 112 | 46 | 61 | 70 |
Maximum Output Speed (RPM) | 60 | 37.5 | 30 | 25 | 18.75 | 60 | 37.5 | 30 | 25 | 60 | 37.5 | 30 | 25 | 60 | 37.5 | 30 |
Repeat Positioning Accuracy (‘’) | 13
| |||||||||||||||
Brake | Electromagnetic Tooth-Meshing Brake | |||||||||||||||
Supply Voltage (V) | 48 | |||||||||||||||
Communication | EtherCAT/CAN | |||||||||||||||
High-Speed End Encoder Resolution (bit) | 19 | |||||||||||||||
Low-Speed End Encoder Resolution (bit) | 19 | |||||||||||||||
Operating Ambient Temperature (°C) | -10~50 | |||||||||||||||
Torque Sensor | Current Detection | |||||||||||||||
Noise (dB) | 70 | |||||||||||||||
Output Rotation Angle (°) | ±180 | |||||||||||||||
Weight (kg) | 1.55/1.6 | 0.95/1.0 | 0.65/0.69 | 0.4/0.38 | ||||||||||||
Output Adapter End Cover | Flange End Cover / Cylindrical End Cover | |||||||||||||||
Product Display
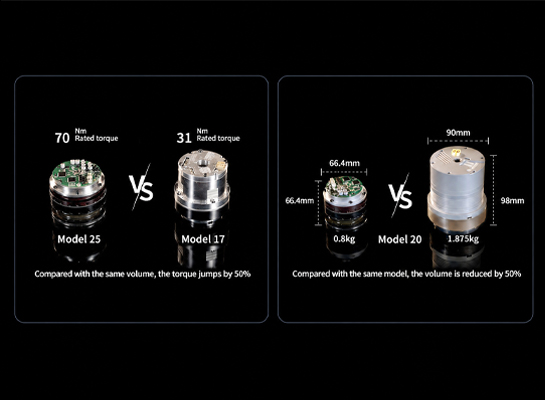
High Torque Density and Lightweight Design
●Maximum Rated Torque: 86 N·m,Maximum Peak Start/Stop Torque: 229 N·m.
●Minimum Weight: 0.4 kg,Minimum Outer Diameter: 55 mm.
●Rated Motor Speed: 3,000 RPM.
●Multiple Gear Ratios Available: 50 / 80 / 100 / 120 / 160.
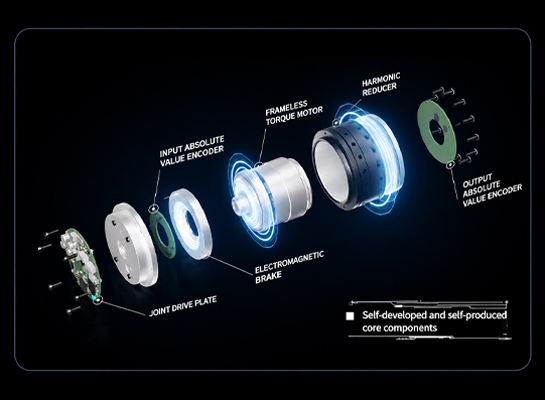
High-Precision Dual Encoders for Accurate Position Feedback
●19-bit High-Resolution Dual Encoders.
●High Repeatability of 13 Arcseconds (13″).
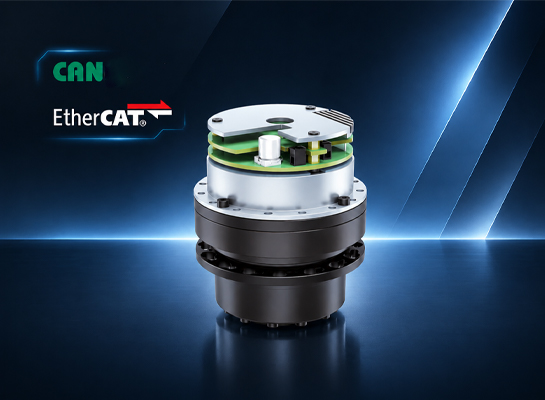
High-Performance Real-Time Control and Multi-Protocol Communication
●Supports synchronous cyclic torque, velocity, and position control, with a minimum control cycle of 1 ms.
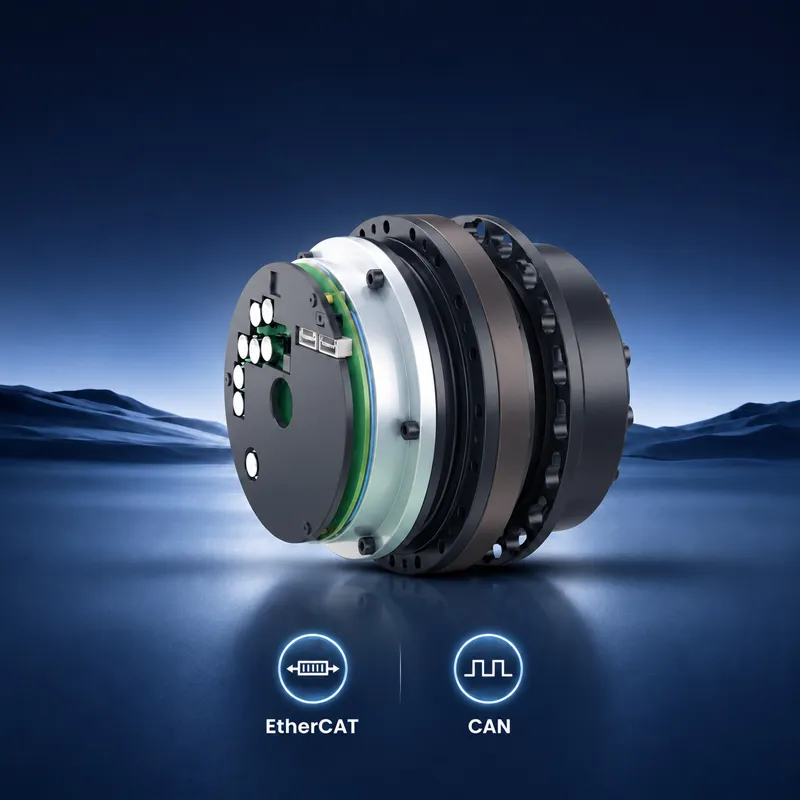
●Supports EtherCAT and CAN Communication.
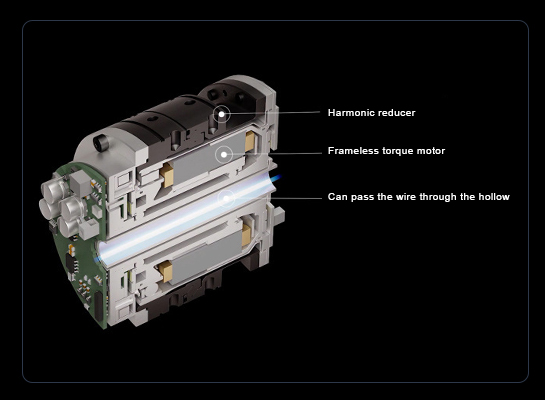
Integrated Electromagnetic Brake and Simplified System Integration
●Built-in Brake Maintains Joint Position When Power Is Disconnected.
●Optional flange-type and cylindrical end covers.
●Simplified Electrical Interface: Only One Power Cable and One Communication Cable Are Required for Control.
Application Cases
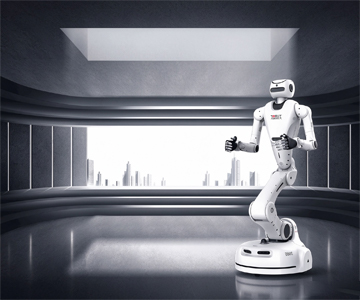
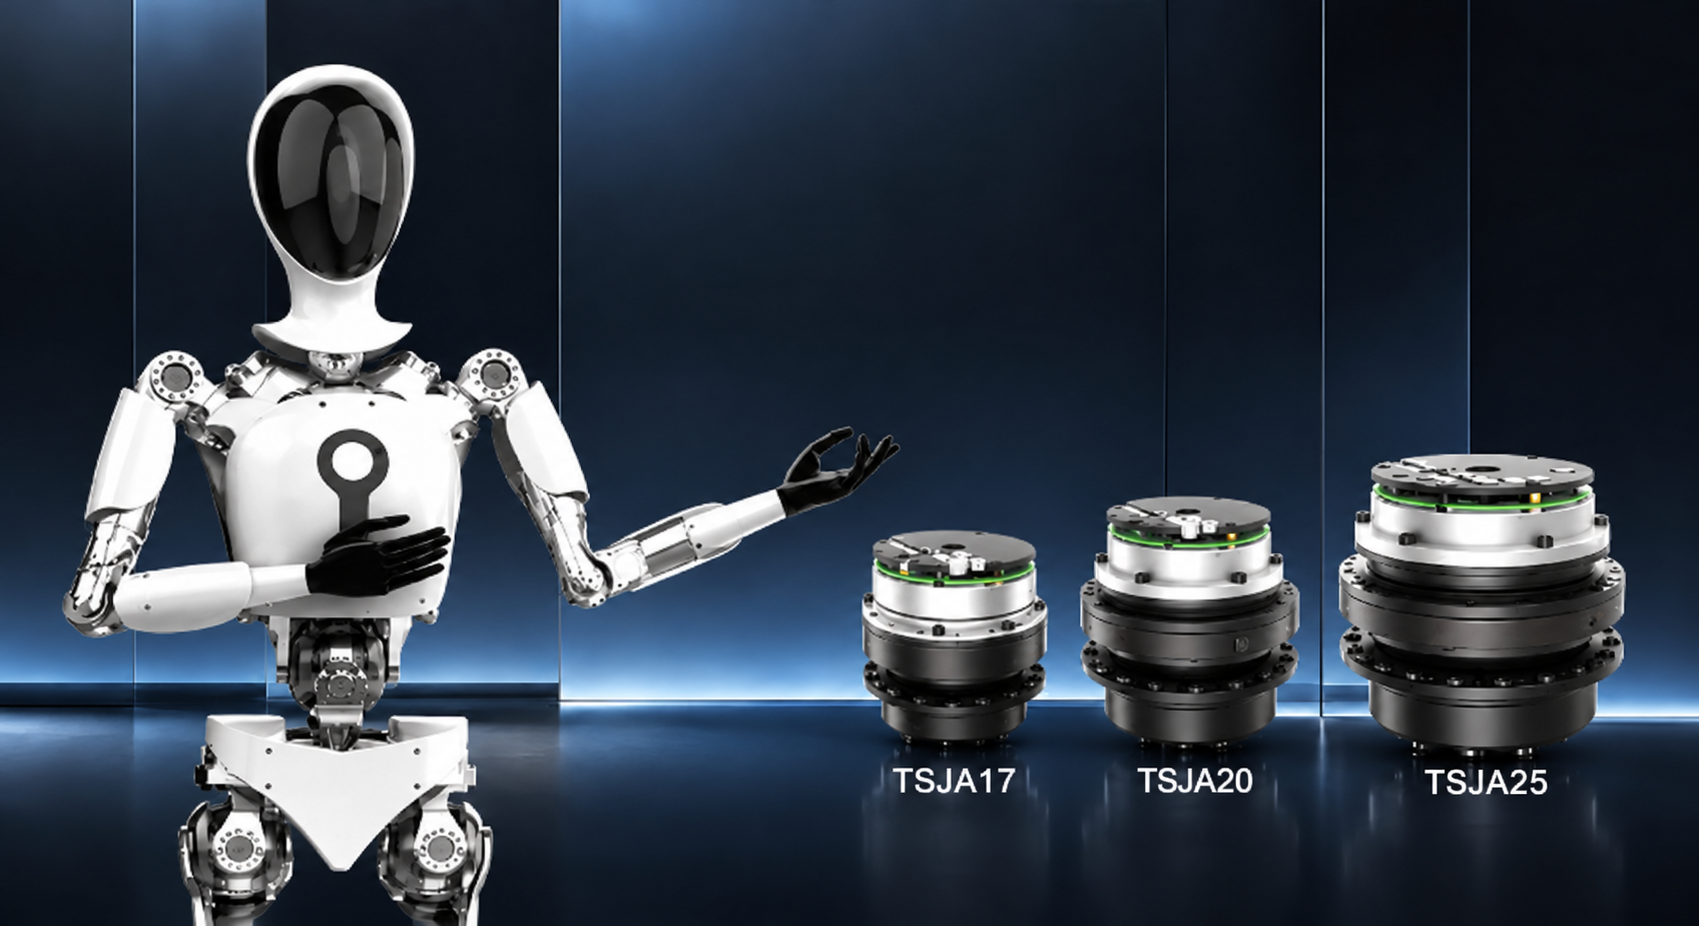
Humanoid robot
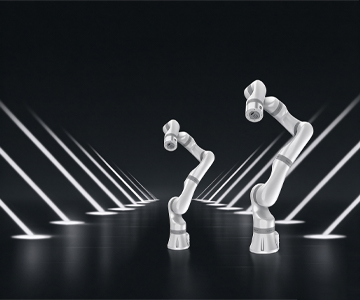
Composite robot
Ultra-Lightweight Collaborative Robot