

Product Description

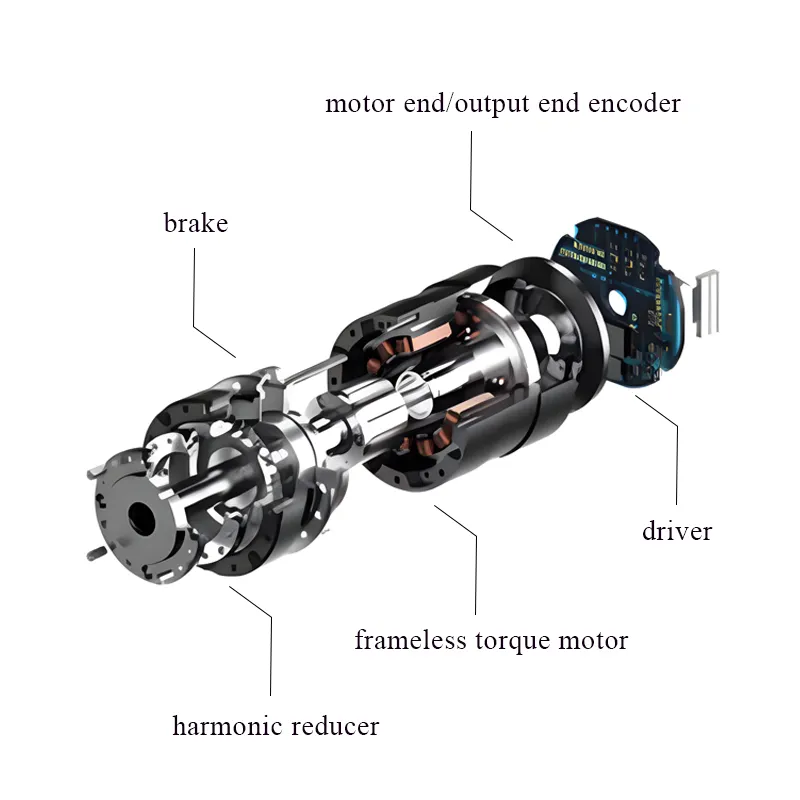
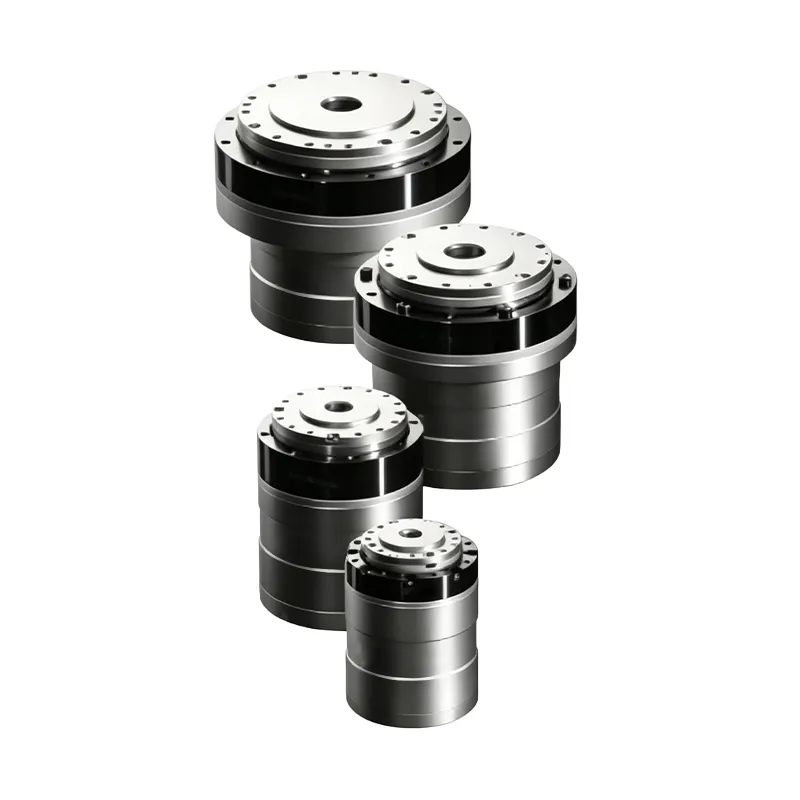
Our actuator is positioned as a miniaturized professional power module. We conduct research and development innovation from the underlying structure of core components, ensuring performance while controlling the overall volume of the product to the greatest extent, allowing you to obtain a more powerful power system within a limited space.
Product parameters
Unit | HA-40 | HA-52 | HA-70 | HA-80 | |||||
Model Parameter | HA-40-50 | HA-40-100 | HA-52-50 | HA-52-100
| HA-70-50
| HA-70-100
| HA-80-50
| HA-80-100
| |
Rated Torque at 2000 rpm | Nm | 1.8 | 2.4 | 3.7 | 5.4 | 11 | 16 | 17 | 28 |
Limit for Repeated Peak Torque | Nm | 3.3 | 4.8 | 12 | 19 | 23 | 37 | 39 | 57 |
Limit for Average Torque | Nm | 2.3 | 3.3 | 4.8 | 7.7 | 18 | 27 | 24 | 34 |
Limit for Momentary Peak Torque | Nm | 6.6 | 9 | 17 | 30 | 30 | 60 | 69 | 95 |
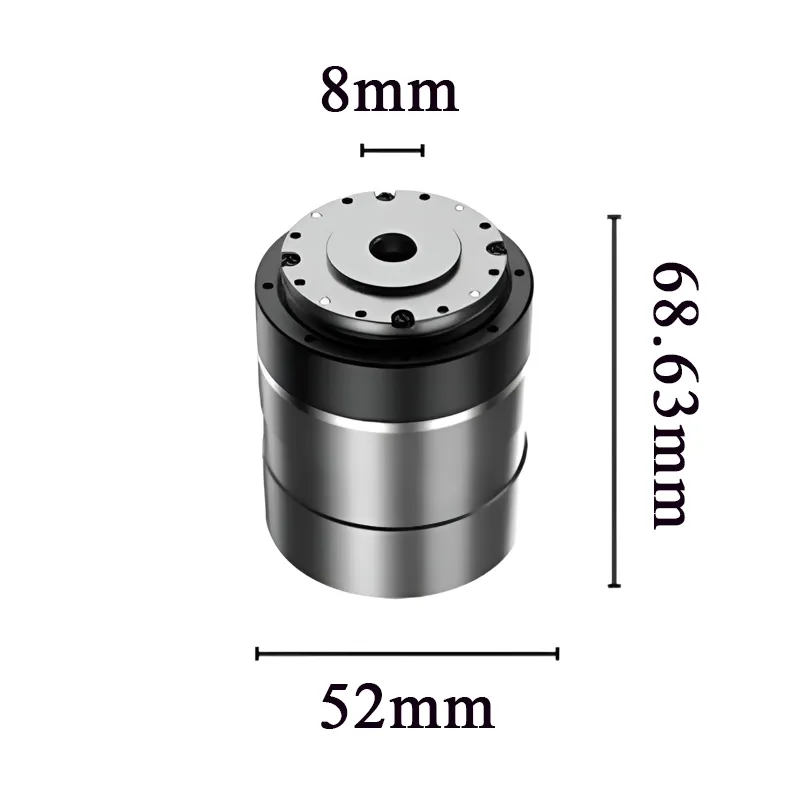
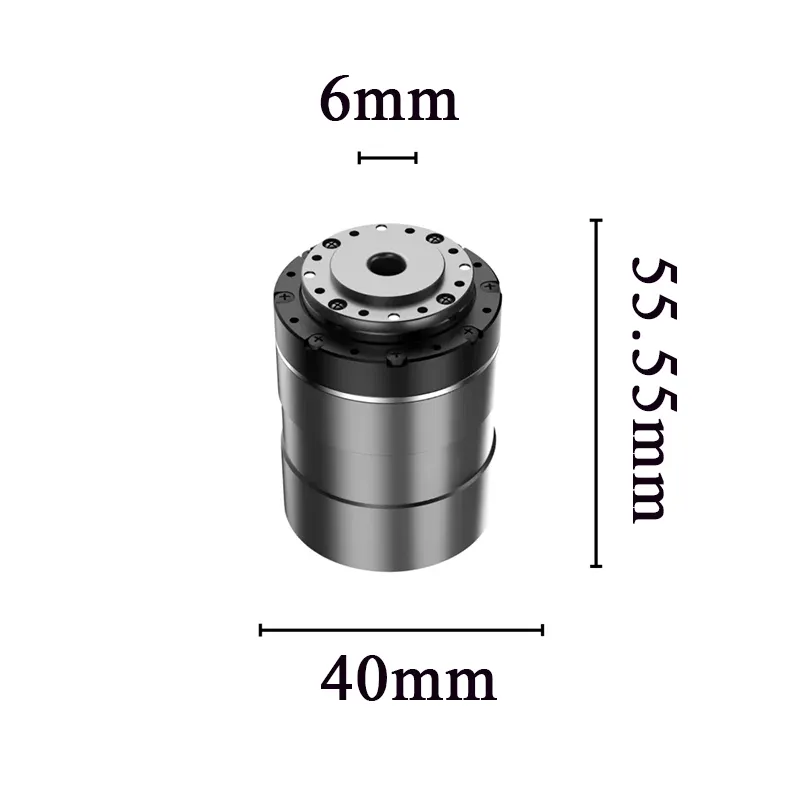
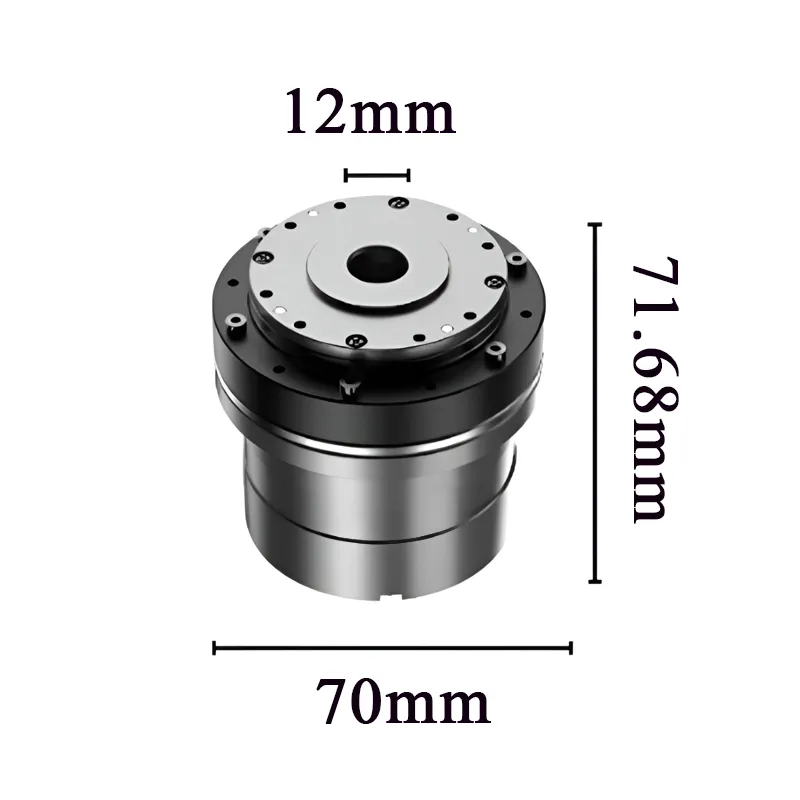
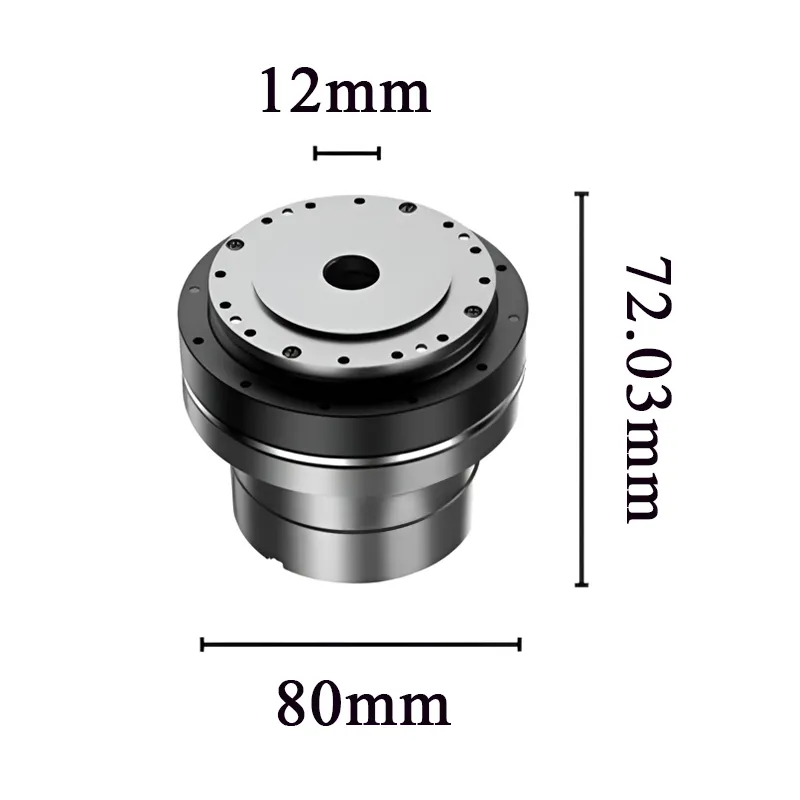
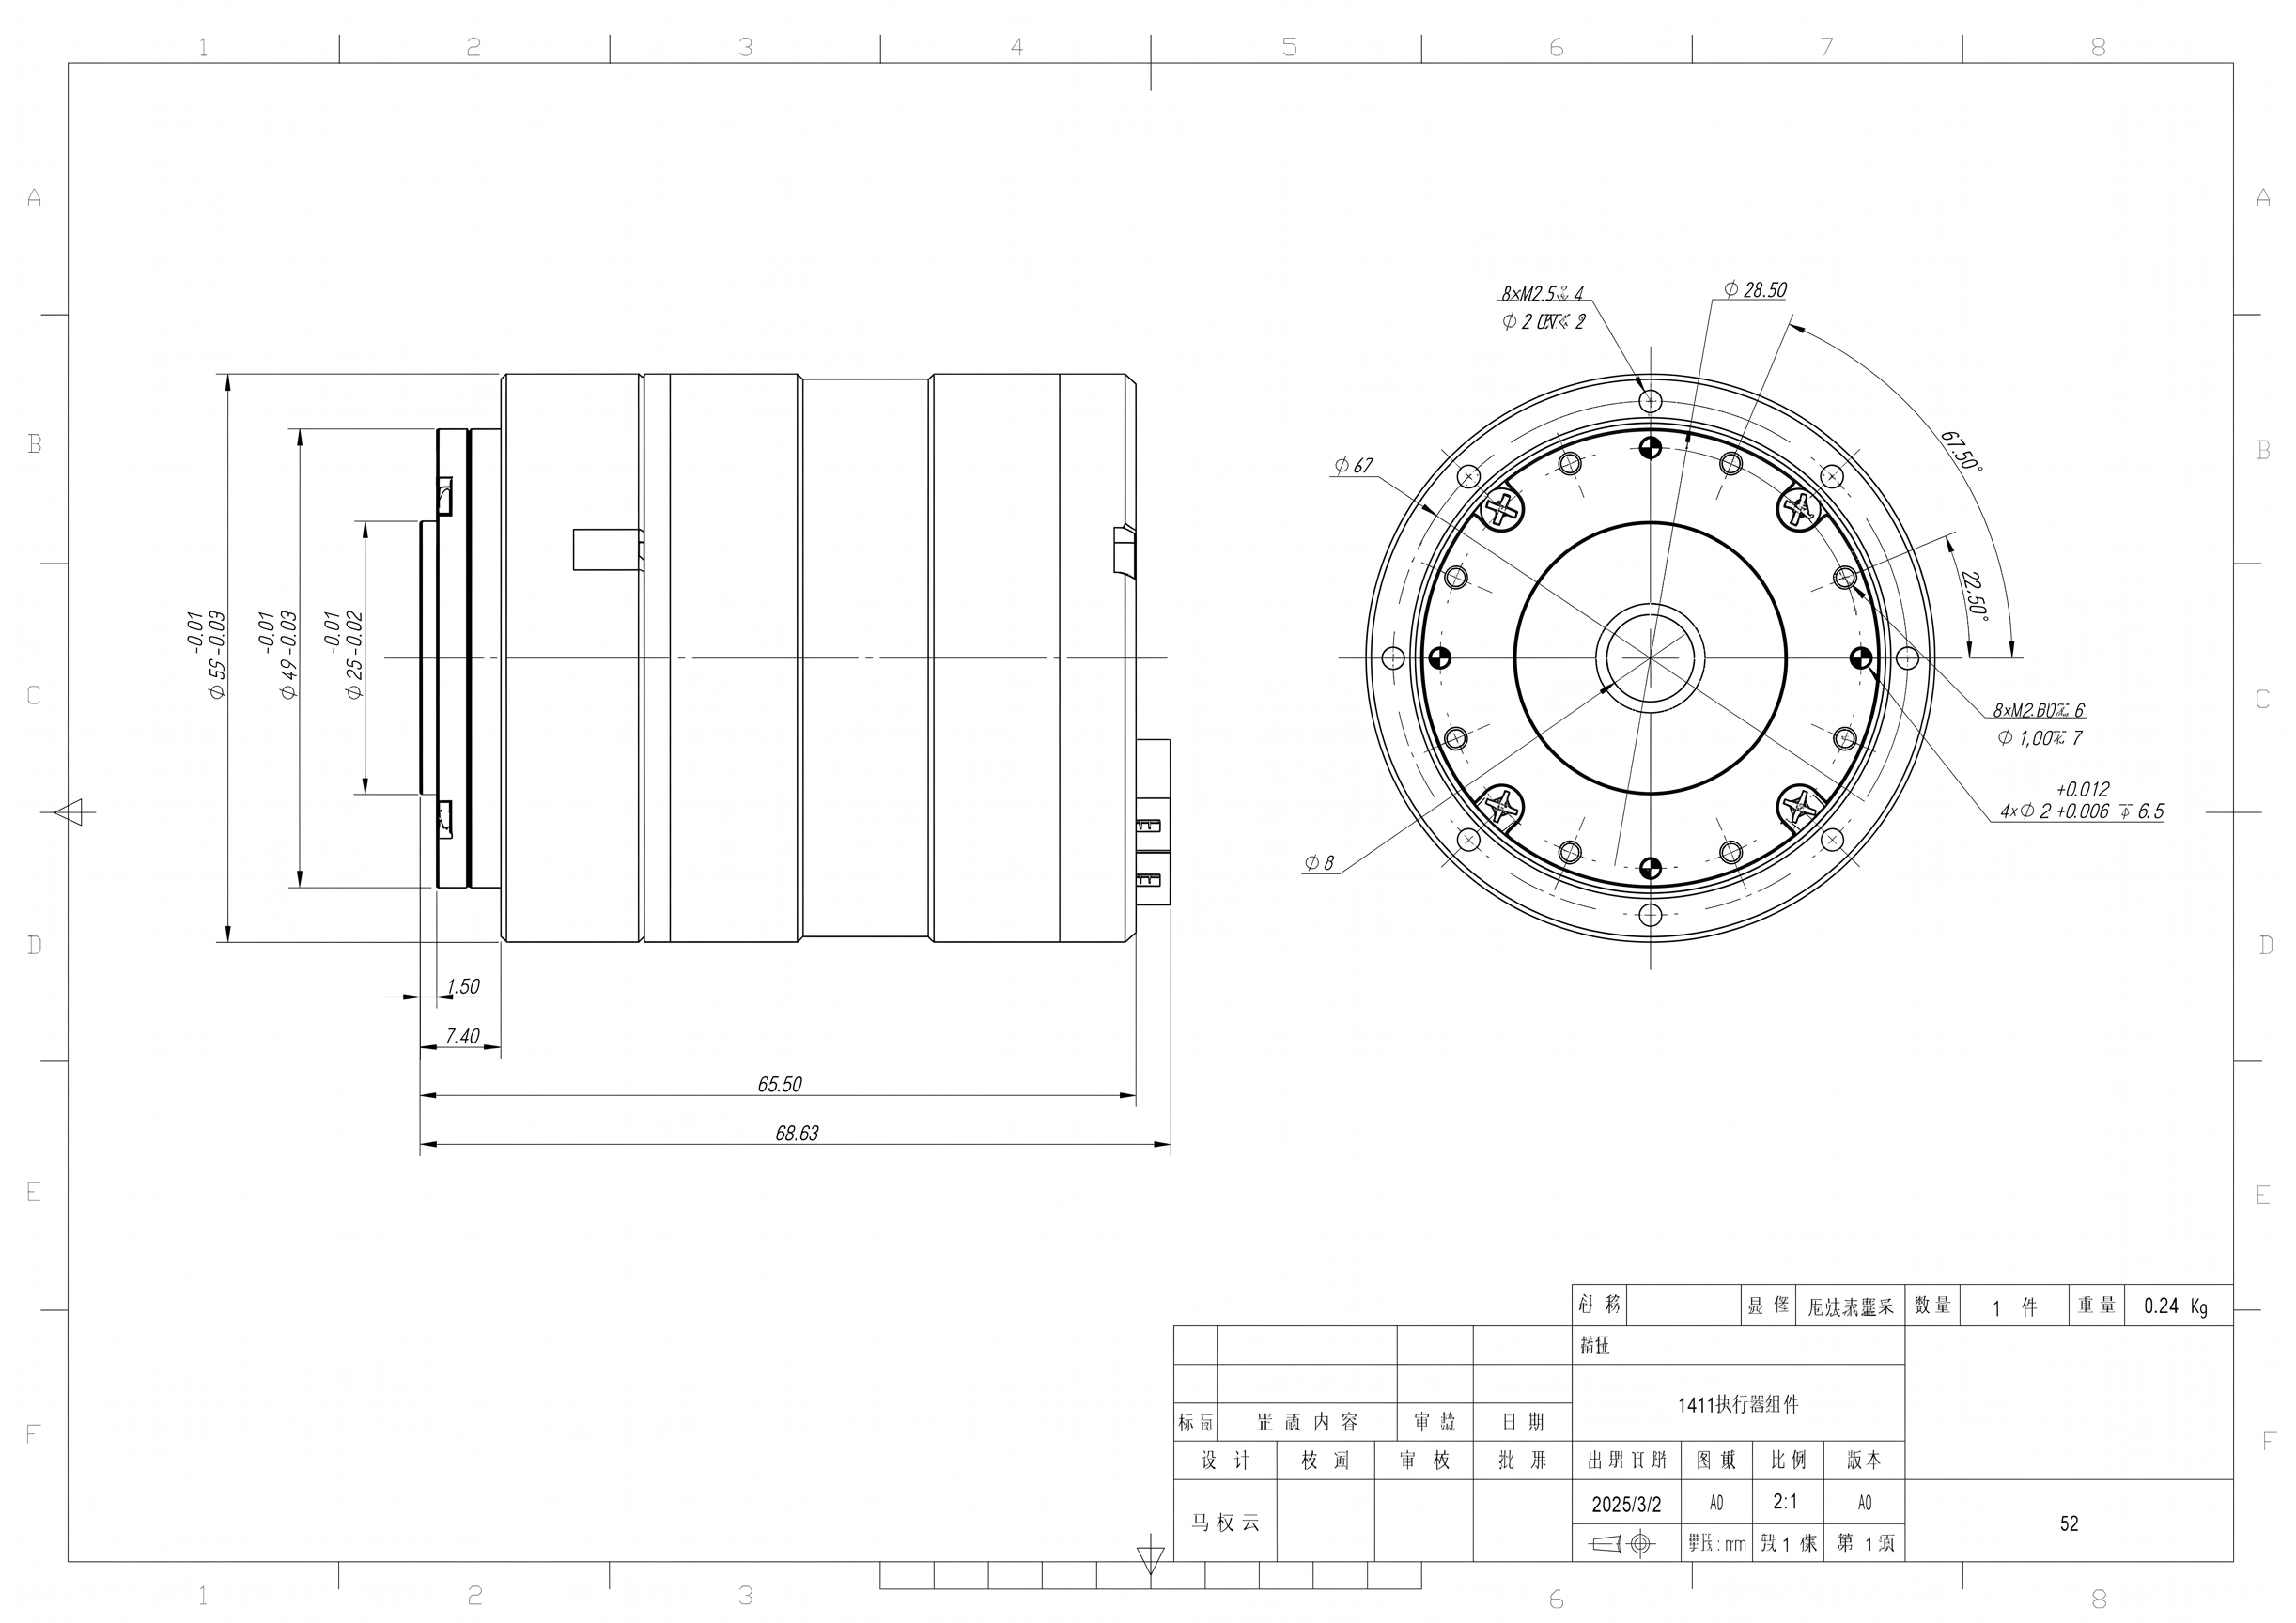
Diameter | mm | 40 | 40 | 52 | 52 | 70 | 70 | 80 | 80 |
Length | mm | 55.55 | 55.55 | 68.63 | 68.63 | 71.68 | 71.68 | 72.03 | 72.03 |
Hollow hole diameter | mm | 6 | 6 | 8 | 8 | 12 | 12 | 12 | 12 |
Weight without brake version | kg | 0.21 | 0.21 | 0.47 | 0.47 | 0.72 | 0.72 | 1.05 | 1.05 |
Weight with brake version | kg | 0.23 | 0.23 | 0.5 | 0.5 | 0.76 | 0.76 | 1.1 | 1.1 |
Maximum working temperature | °C | 80 | 80 | 80 | 80 | 80 | 80 | 80 | 80 |
Minimum working temperature | °C | -40 | -40 | -40 | -40 | -40 | -40 | -40 | -40 |
Lifetime | h | 7000 | 7000 | 7000 | 7000 | 7000 | 7000 | 7000 | 7000 |
Installation method | arcsec | Flange Mounting | |||||||
Repeat positioning accuracy | arcsec | 35 | 18 | 35 | 18 | 30 | 15 | 25 | 15 |
Absolute positioning accuracy | arcsec | 120 | 100 | 120 | 100 | 120 | 100 | 100 | 90 |
Communication model | / | CAN2.0B | |||||||
Baudrate | bps | 1M | |||||||
Maximum output Speed | rpm | 80 | 40 | 80 | 40 | 80 | 40 | 80 | 40 |
Supply voltage | V | 24-48 | |||||||
Rated Power | w | 30 | 25 | 30 | 25 | 60 | 72 | 90 | 100 |
Peak Power | w | 90 | 80 | 170 | 160 | 190 | 240 | 280 | 270 |
IP Rating
| IP54 | ||||||||
Product Views

Small Space, Large Torque
With a diameter of less than 80mm, it can generate a torque of 95Nm. This is simply unimaginable!

Minimal Space,Maximum Power
Measured power under rated conditions<30W

Stable Performance & High Temperature Resistance
It has an extremely strong temperature resistance and can operate stably throughout the full temperature range of -35℃ to 80℃

Longer Working Life
The working time under the measured rated working conditions can reach 7000h

More Comprehensive & Easier to Use
·Multiple control modes
·Rich video tutorials
·Easy-to-use host computer software
·Comprehensive documentation support
·Complete SDK for Windows and Linux environments
Quality control

Actuator Torque & High Load Performance Test

Low & High Temperature Test

High Load & Precision Running Test

Lifespan & Forward/Reverse Rotation Test
Schematic Diagram
Hardware Wiring
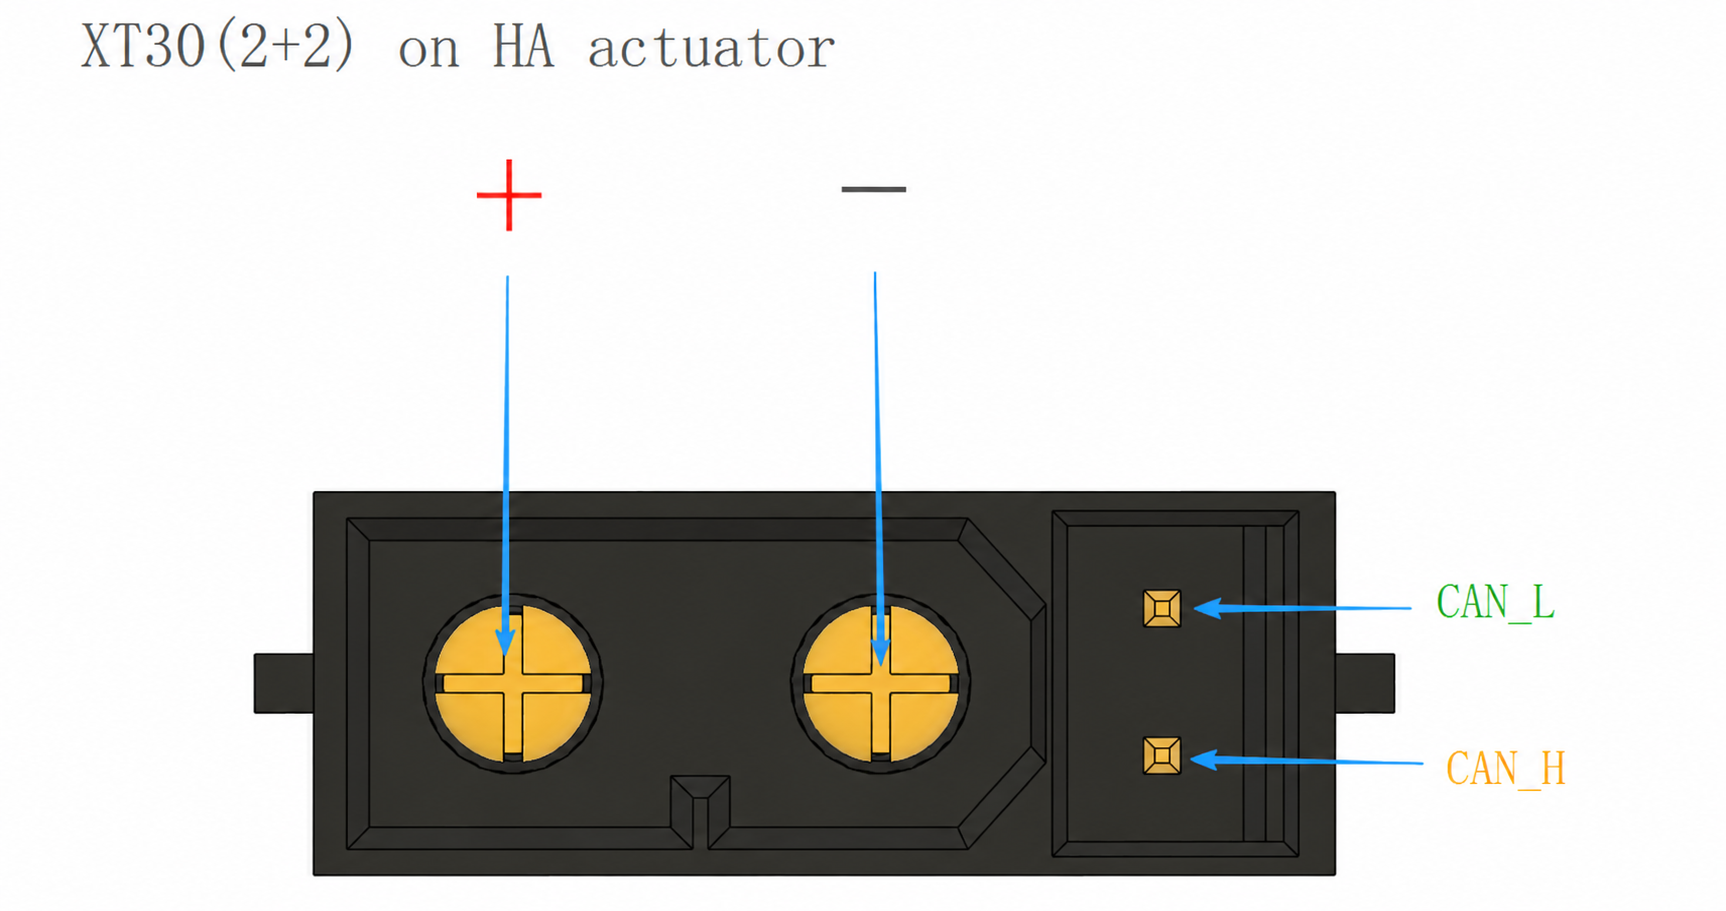
Interface Description:
●Power and Communication Adapter Cable: The actuator uses an XT30 (2+2) male connector. This connector has 2 pins for power and 2 pins for signals. Twisted-pair cables are recommended for signal transmission.
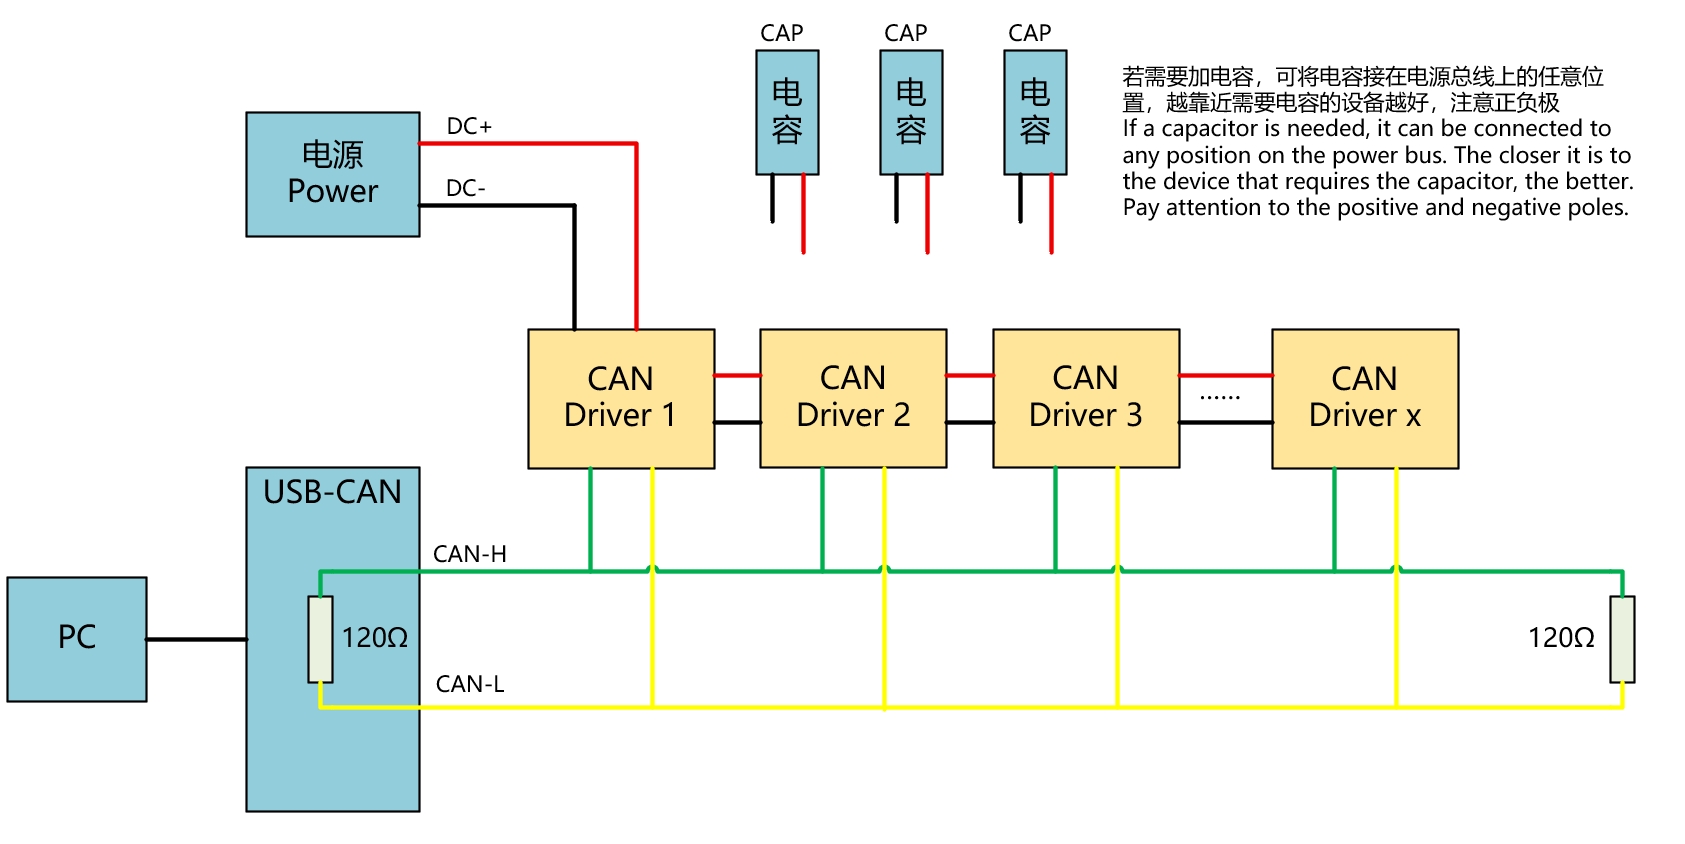
Actuator Wiring Method:
●For actuators with brakes, when using Profile Position, Position, or MIT mode, if automatic brake engagement upon power loss is required, an additional capacitor needs to be connected. The capacitor size needs to be determined according to the actual usage scenario.
●According to the basic CAN communication protocol, 120-ohm resistors need to be connected at both ends of CAN_L and CAN_H.
●If there is strong magnetic field interference in the actuator's working environment, it is recommended to cover the CAN communication cable with a shielded cable to avoid data transmission errors.
Application Cases

Guadruped Robot

Collaborative Robot

Driverless Vehicle
Company Introduction
PROVEN SOLUTION FOR JOINT ACTUATORS
Our company's power integration technology has served many well-known robot companies. The actuators have achieved an excellent balance between size and performance design, enabling structural engineers to play a greater role.