

Product Description

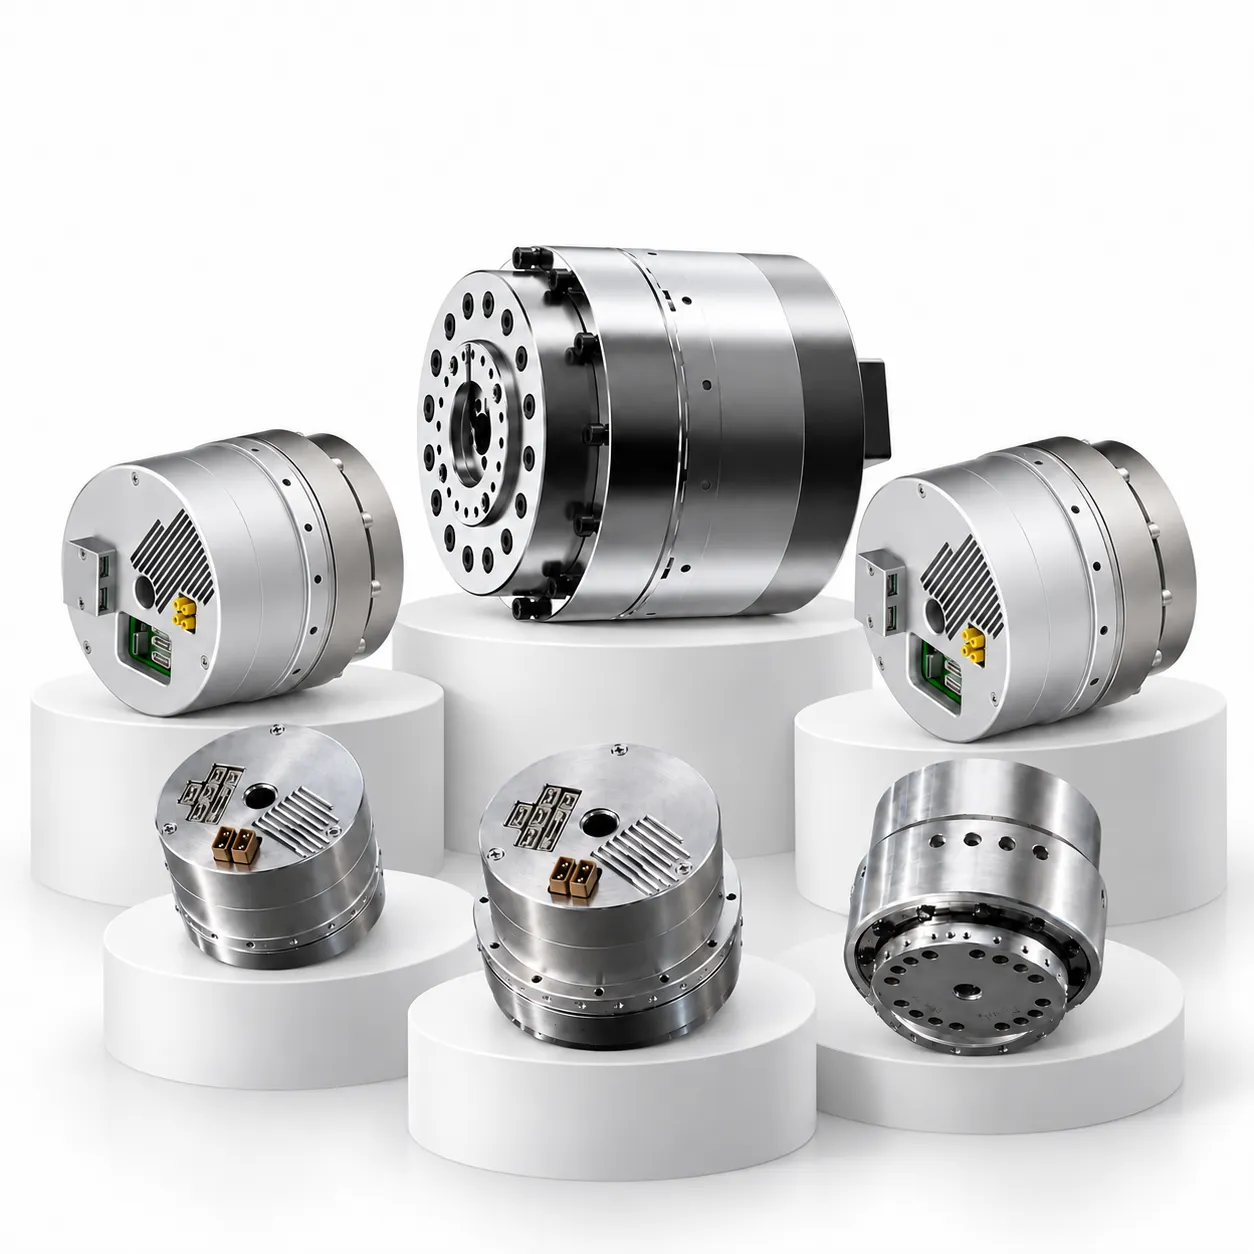
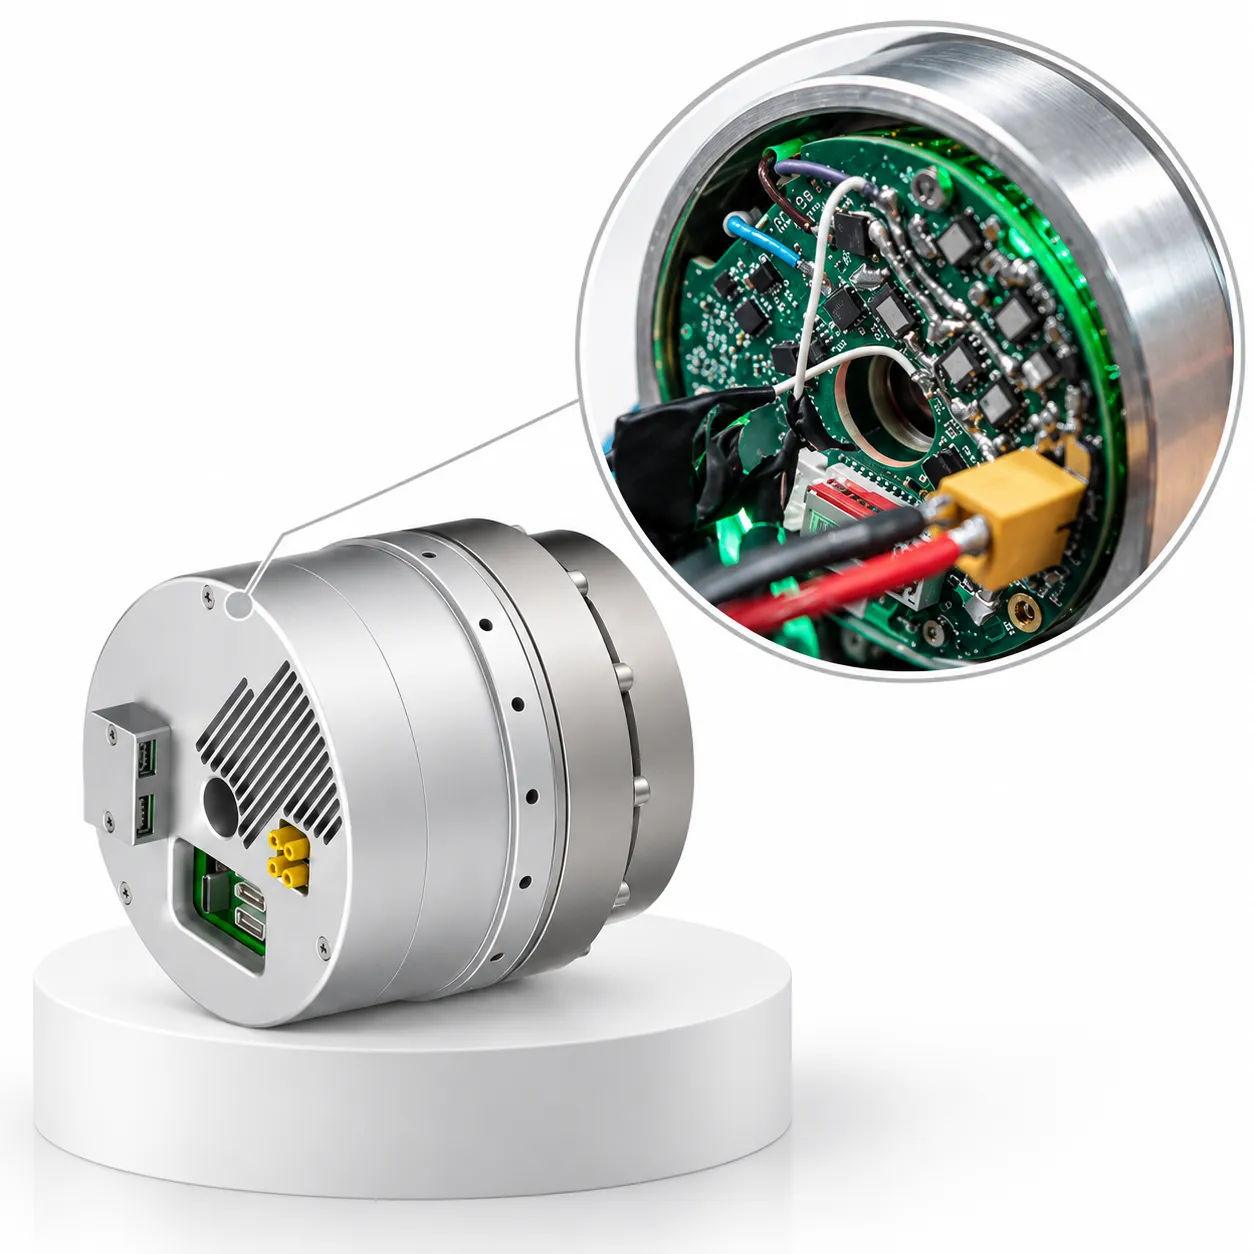
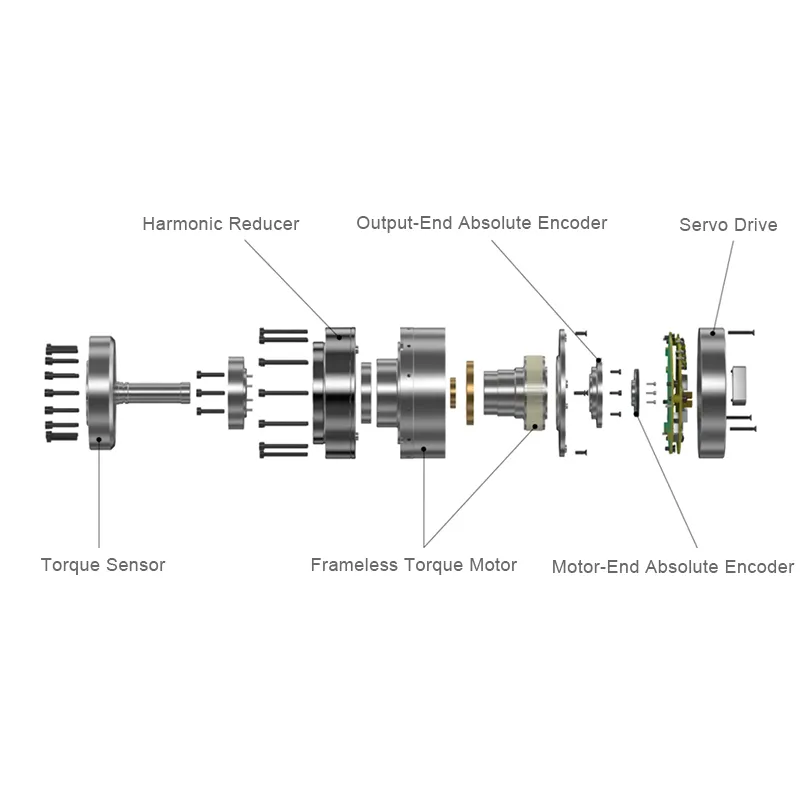
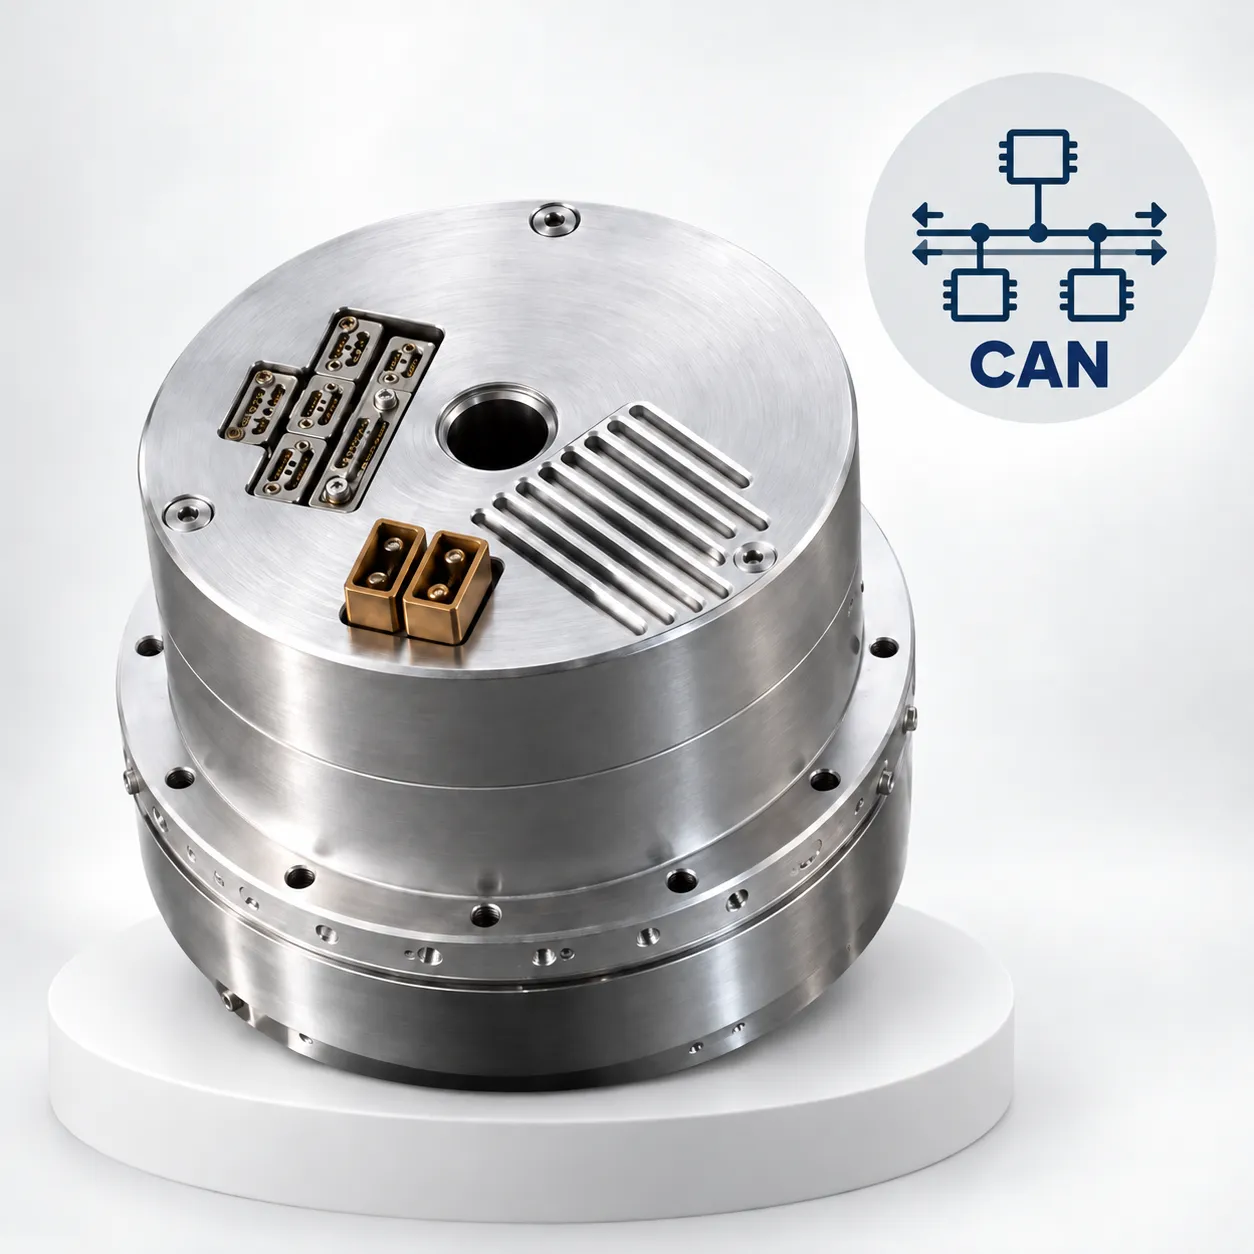
The force-controlled rotary actuator features a highly integrated design that combines a frameless torque motor, harmonic reducer, encoder, servo drive, and core force-control components into a compact joint module. Based on a self-developed high-torque-density motor, force-control algorithms, and high-ratio transmission solution, it delivers stable high-torque output at low speeds while providing precise force, position, and speed control. Four models are available to meet the requirements of different humanoid robot joints, including the shoulder, leg, waist, elbow, hip, and ankle.

①Torque Sensor ②Harmonic Reducer ③Frameless Torque Motor ④Output-End Absolute Encoder ⑤Motor-End Absolute Encoder ⑥Servo Drive
Product parameters
Specification | FXR-14 | FXR-17 | FAL-20 | FXL-25 | |
Dimension Specifications | Weight (kg) | 0.86 | 1.25 | 1.75 | 2.7 |
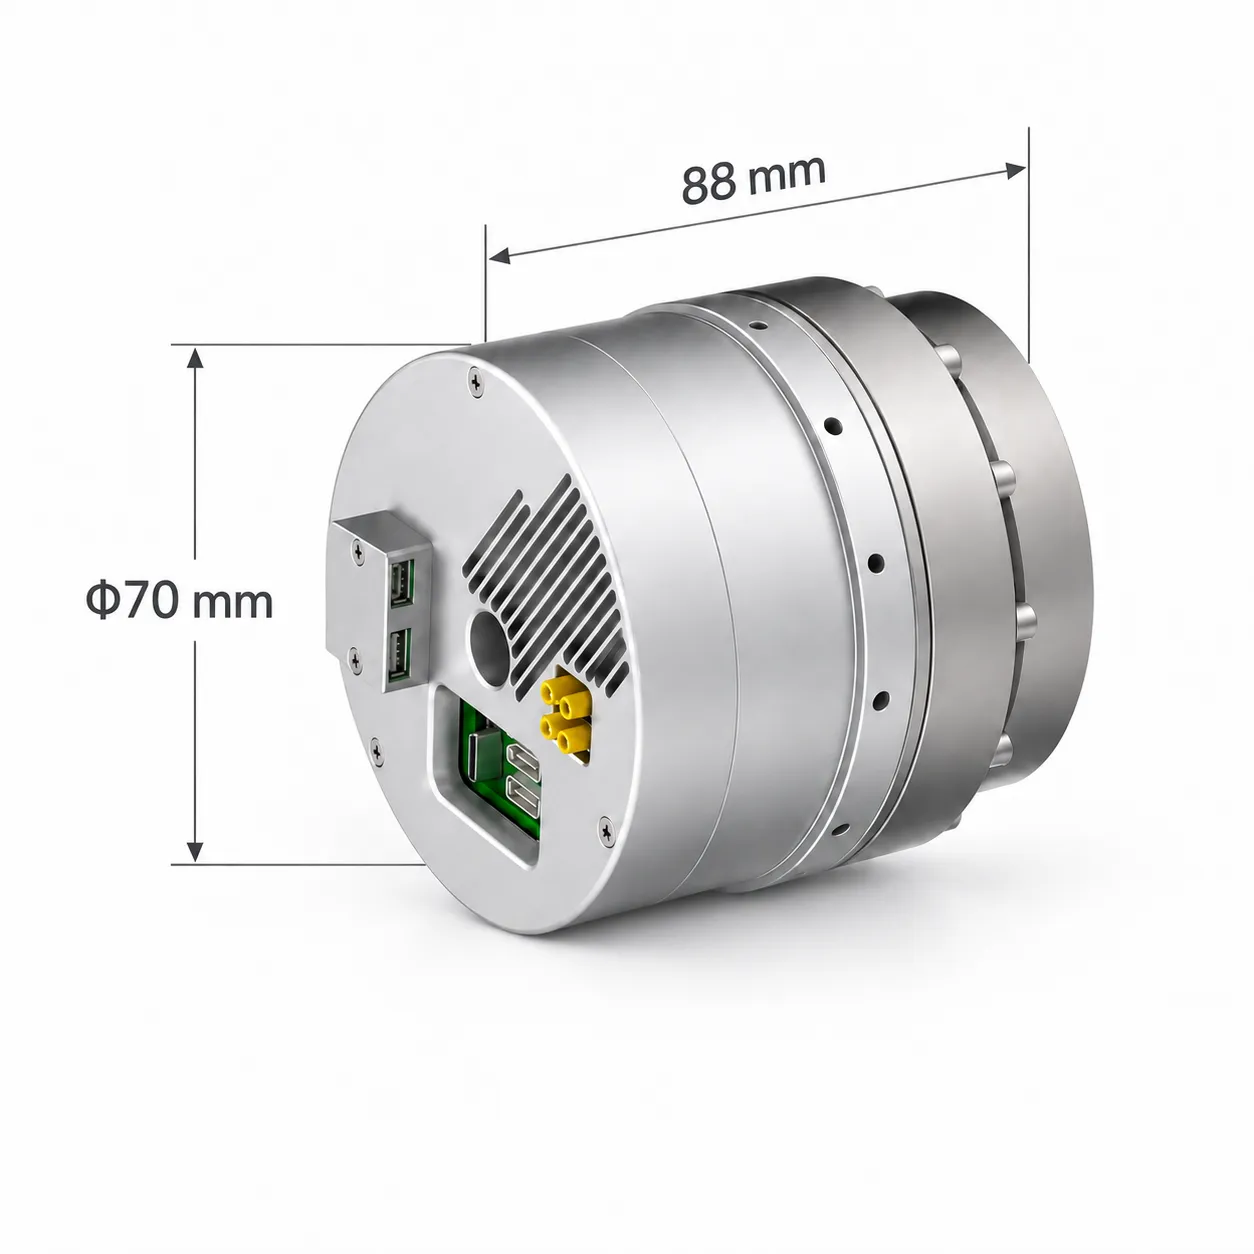
Overall Dimensions (Excluding Brake and Torque Sensor) (mm) | Φ70×88 | Φ80×98 | Φ90×98 | Φ110×107 | |
Hollow Diameter (mm) | Φ6 | Φ9.5 | Φ9.5 | Φ12.5 | |
Reduction Ratio | 30-120 | 30-120 | 30-120 | 30-120 | |
Torque | Rated Torque (N.m) | 9.6 | 30 | 50 | 84 |
Maximum Output Speed (rpm) | 34.6 | 29.7 | 29.7 | 29.7 | |
Average Load Allowable Maximum Torque (N.m) | 13.5 | 49 | 61 | 133 | |
Maximum Allowable Torque During Start/Stop (N.m) | 34 | 66 | 102 | 194 | |
Instantaneous Allowable Maximum Torque (rpm) | 66 | 134 | 182 | 351 | |
Encoder | Encoder Type | Magnetic Encoder | Magnetic Encoder | Magnetic Encoder | Magnetic Encoder |
Encoder Resolution | 17bit | 17bit | 17bit | 17bit | |
Dual Encoder | Yes | Yes | Yes | Yes | |
Force Sensor | Torque Sensor | Optional | Optional | Optional | Optional |
Force Control Accuracy (F.S.) | 0.2 | 0.2 | 0.2 | 0.2 | |
Repeat Positioning Accuracy (arcsec) | 20 | 20 | 20 | 20 | |
Brake | Brake | Optional | Optional | Optional | Optional |
Electrical Parameters | Rated Voltage (VDC) | 48 | 48 | 48 | 48 |
Rated Output Power (W) | 49 | 177 | 221 | 483 | |
Maximum Output Power (W) | 103 | 314 | 471 | 785 | |
Product Views

Integrated Force Control & Drive System
Supports deep integration of the force sensor, force-control algorithms, and servo drive, achieving a high level of integration across sensing, control, and actuation. It enables precise force, position, and speed control to meet the control requirements of robots in high-dynamic and variable-load applications.

High Torque Density & Stable Output
Adopts a self-developed high-torque-density motor and a high-ratio harmonic transmission system to achieve high torque output within a compact structure. It supports stable high-torque operation at low speeds, meeting the requirements of robotic joints for high power performance and motion stability.

Dual-Encoder Feedback & Precise Control
Adopts a dual-encoder closed-loop feedback design to monitor the position status of the motor and output ends in real time, providing high-precision feedback for joint motion control. Combined with advanced control algorithms, it enables precise position control and stable motion response.

Highly Integrated & Versatile
Integrates key components including the frameless torque motor, harmonic reducer, encoders, and servo drive into a compact joint module, while supporting rapid customization. Four models cover different torque levels and can be selected to meet the requirements of different humanoid robot joints, including the shoulder, waist, elbow, hip, knee, and ankle.
Application Cases

Bipedal Humanoid Robots

Elderly Care Service Robots

Special-Purpose Robots